

Interactive Device: Light Distance Away


Type
Interactive Electronic Device
Year
2020
Skills
Programming (C++), Soldering, Arduino
Softwares
Arduino IDE; Processing; Adobe Creative Suite
Context
In our current pandemic situation where loved ones cannot easily be with each other physically, our device (and setup) aims to stimulate your loved one’s walking movements in your room. It seeks to highlight distant bodies through the absence of the body.
How the device works
Walking around the space, one’s footsteps are translated into a path of light in a distant room. In both rooms, a path generated by your loved one begins to form and a pair of shoes follow suit. Watching the shoes move, the distant movement is transported by light to the room one is currently present in. The presence of another body either haunts or comforts us through its absence represented by the shoes. The physical distance between is shortened to a lighted path as both distant bodies now move together in their respective rooms.
Light Distance Away device (footwear)

Demo
Hardware (per set)
DC Motors x 2
Wheels x 3
Light Dependent Resistor x 4
DF Robot Motor Driver Shield x 1
Arduino Uno x 1
Pixy Camera x 1
Projector x 1
Slipper x 1
Software
Arduino IDE
Processing
Tool
Soldering Equipment
Sewing kit (to stitch slippers together)
Development Process
Setting up the pixy camera for processing to projector

Setting up internal parts
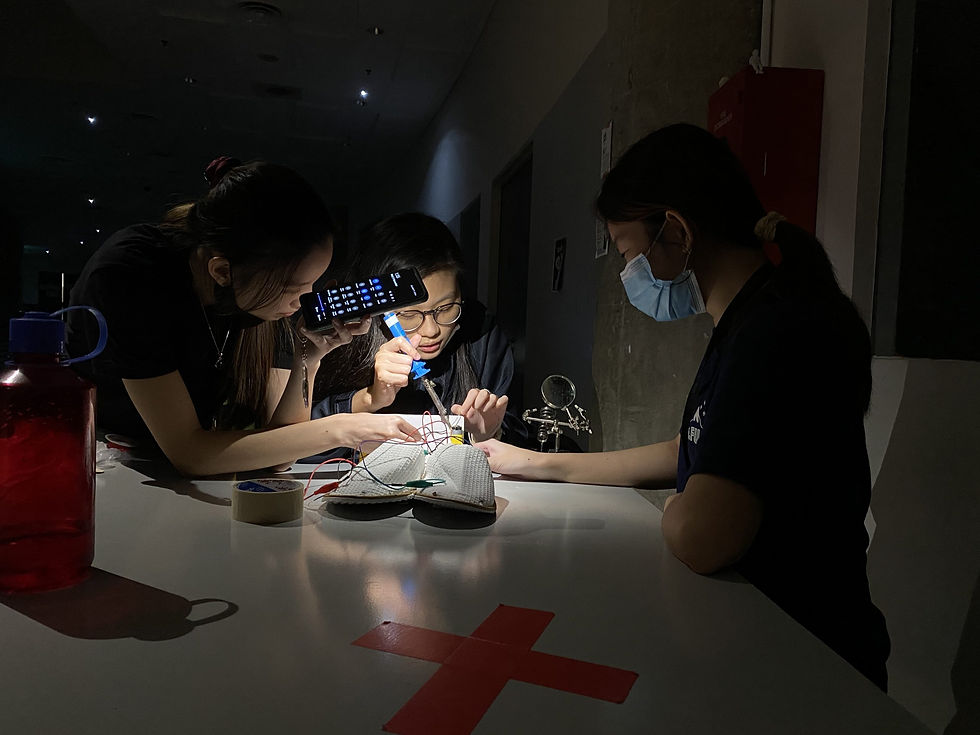
Assemble hardwares: Soldering

Processing to Projector: Testing best fit curve
Transforming dots to curved lines in Processing
Challenges
Choosing right equipment to use : Motor Driver
Indoor Positioning system
Assembling
Wires keep breaking
Results unpredictable as bare wires were touching each other. Had to tape over wires after soldering to ensure that they would not touch and wrongly close the circuit.
Power management. Battery power affecting LDR sensing as well as speed of the motor
If motor too fast, will move past the line
If too slow, it wont even move the shoes
Processing code – sharp edge smoothing
Wheels losing friction and gliding
Quick solution was to tape the wheels with double sided tape
But not a permanent solution as once dust collects on the tape, it will lose its friction again
And if the tape is too strong, then the friction will be too much for our wheels to move
Space limitations
Ideally wanted a more complete set up, with bedroom furniture and more walk space
However, only truss room was the best choice for us as we needed a dark room where we could easily mount our short throw projectors and pixy cam from high above
Had to share truss room with other projects, so markings on the masking tape hindered our robot at times
Final Combined Code
Final Pitch


